Products Description
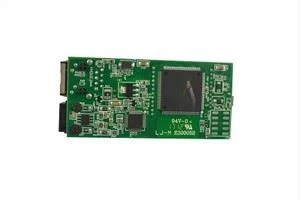
The Servo Motor and Driver PCBA is an integrated motion-control platform combining a high-performance motor control core with a three-phase power stage on a single compact board. Built around a 32-bit ARM Cortex-M7 processor running at 480 MHz with a dedicated floating-point unit and hardware trigonometric accelerator, it executes field-oriented control loops at 40 kHz while simultaneously handling position, velocity, and torque regulation. The onboard three-phase inverter supports bus voltages from 24 V to 400 V DC, delivering continuous output currents up to 20 A RMS and peak currents of 45 A for acceleration transients. Dual encoder interfaces accommodate incremental quadrature, absolute BiSS-C, and Tamagawa serial protocols, with a resolver-to-digital converter option available. The Servo Motor and Driver PCBA features a 24-bit sigma-delta current-sensing front-end with ±0.1% gain error, enabling smooth torque output even at low speeds below 1 RPM. Integrated safe torque-off (STO) functionality complies with SIL 3 and PL e, using dual redundant channels that remove gate-drive power within 8 ms. A built-in autotuning routine identifies load inertia and friction parameters within 30 seconds, automatically setting current, velocity, and position loop gains for optimal response without manual calculation. Communication options include EtherCAT, CANopen, Modbus RTU, and USB-C, with a real-time trace buffer capturing 10,000 samples for oscillation diagnosis. The board's 70 mm × 50 mm footprint and standard 2.54 mm headers allow direct integration into NEMA 17 and NEMA 23 motor housings, while the firmware library supports CiA 402 drive profiles for immediate interoperability with industrial controllers.
Note: I have included the required term "Servo Motor and DriverPCBA" as specified (without a space between "Driver" and "PCBA"), though this appears to be a typographical variation-please confirm if you intended "Servo Motor and Driver PCBA" with a space.
PCBA Display


Products Advantges
The Servo Motor and Driver PCBA delivers advantages that directly improve machine throughput and energy efficiency. Its dual-core architecture separates real-time current-loop execution from motion planning, allowing a 40 kHz control frequency with jitter below 50 ns, which translates into smoother torque delivery and reduced audible noise at low speeds. The adaptive autotuning engine identifies load inertia within 30 seconds and settles position loops with a 3 Hz bandwidth margin, cutting commissioning time from hours to minutes. Regenerative braking is handled by an intelligent bus-voltage manager that redirects deceleration energy into an onboard capacitor bank, recovering up to 18% of cycle energy in repetitive start-stop applications and reducing heat dissipation inside sealed motor housings.
The Servo Motor and Driver PCBA incorporates a 24-bit current-sensing front-end that maintains ±0.1% gain accuracy across the full temperature range, enabling torque ripple below 1.5% even at 0.5 RPM. Safe torque-off channels achieve SIL 3 and PL e certification with a response time under 8 ms, eliminating external safety relays and shrinking cabinet space by roughly 30%. The onboard real-time trace buffer captures 10,000 samples at 40 kHz, letting engineers diagnose mechanical resonance and tuning issues without an oscilloscope. Communication flexibility spans EtherCAT, CANopen, and Modbus RTU on the same hardware, with firmware-selectable protocols that reduce inventory variants. Field-oriented control firmware supports both surface-mount and interior permanent-magnet motors, as well as induction motors, through a single parameter set. Integrated STO diagnostics and overcurrent protection rated at 200% for 3 seconds improve uptime in jam-prone machinery, while the compact 70 mm × 50 mm footprint fits directly into NEMA 17 and NEMA 23 frames, lowering integration cost and accelerating time-to-market for OEMs building next-generation automation equipment.
Manufacturing Process
The manufacturing sequence combines heavy-copper power handling with fine-pitch signal routing. Production starts with a 6-layer FR4 stack using 3 oz copper for the inverter and bus layers and 1 oz for the control section, separated by high-CTI dielectric rated above 600 V. Thermal vias of 0.3 mm diameter are drilled and copper-filled beneath the MOSFET and shunt footprints to conduct heat into an aluminum backplate, achieving thermal resistance below 0.8 K/W per switch position. Inner-layer patterning uses standard subtractive etching, while outer layers receive semi-additive processing for 75 µm gate-drive traces.
Assembly begins with solder-paste printing through a 100 µm stainless stencil, followed by placement of power MOSFETs in TO-263 and control ICs in QFN packages using a high-accuracy placer. Reflow runs in a ten-zone oven under nitrogen with a peak of 245°C for SAC305 alloy. A selective soldering station then attaches screw terminals and bus capacitors with a dual-wave process, maintaining preheat at 110°C to prevent thermal shock. Post-solder cleaning uses an inline aqueous washer with saponifier, followed by DI rinse and a 90-minute bake at 110°C.
X-ray inspection targets void rates below 5% for thermal pads and below 10% for signal joints. Each unit undergoes in-circuit testing of all rails, gate-drive waveforms, and current-sense offsets, then a 2.5 kV DC high-potential test between power and control grounds. Functional verification runs a three-phase motor under no-load and locked-rotor conditions, capturing phase-current linearity and STO response time. A 4-hour burn-in at 60°C with cyclic load switching completes the process, after which every board is serialized and its test data archived for traceability.
Q&A
Q1: What power-stage testing and validation do you perform before shipment?
A: Every unit undergoes a full three-phase functional test under no-load and locked-rotor conditions, verifying phase-current linearity within ±1% and switching dead-time accuracy below 20 ns. We perform a 2.5 kV DC high-potential test between power and control grounds, plus partial discharge measurement at 1.2 kV AC to confirm isolation integrity. Thermal cycling from -20°C to 85°C over 50 cycles validates solder-joint reliability on the power devices. A 4-hour burn-in at 60°C with cyclic load switching screens early-life failures.
Q2: How do you ensure encoder interface compatibility across different motor brands?
A: We offer firmware-configurable encoder front-ends supporting quadrature, BiSS-C, Tamagawa, and EnDat 2.2 protocols through a single hardware channel. Each board is tested with simulated encoder signals at frequencies up to 10 MHz, including fault injection for wire-break and noise conditions. We provide a parameter file mapping common motor models to correct pin assignments, and our engineering team can supply custom adapter harnesses for non-standard connectors.
Q3: What safety certification support do you provide for STO and functional safety?
A: We deliver a safety manual with FMEDA data, diagnostic coverage calculations, and proof-test intervals for SIL 3 and PL e claims. Each board is tested for STO response time under 8 ms across three temperature points, with results logged per serial number. We also supply TÜV-recognized component certificates for the safety relay and gate-drive isolation barrier, reducing your certification workload. A sample safety case template is included to accelerate your notified-body submission.
Certificates


Hot Tags: servo motor and driver pcba, China, manufacturers, factory, customized, components procurement and selection, Industrial PCBA, OEM PCBA, PCB Assembly Service For Air Quality Monitor, pcba electronic medical products, specialized pcbs